Introduction
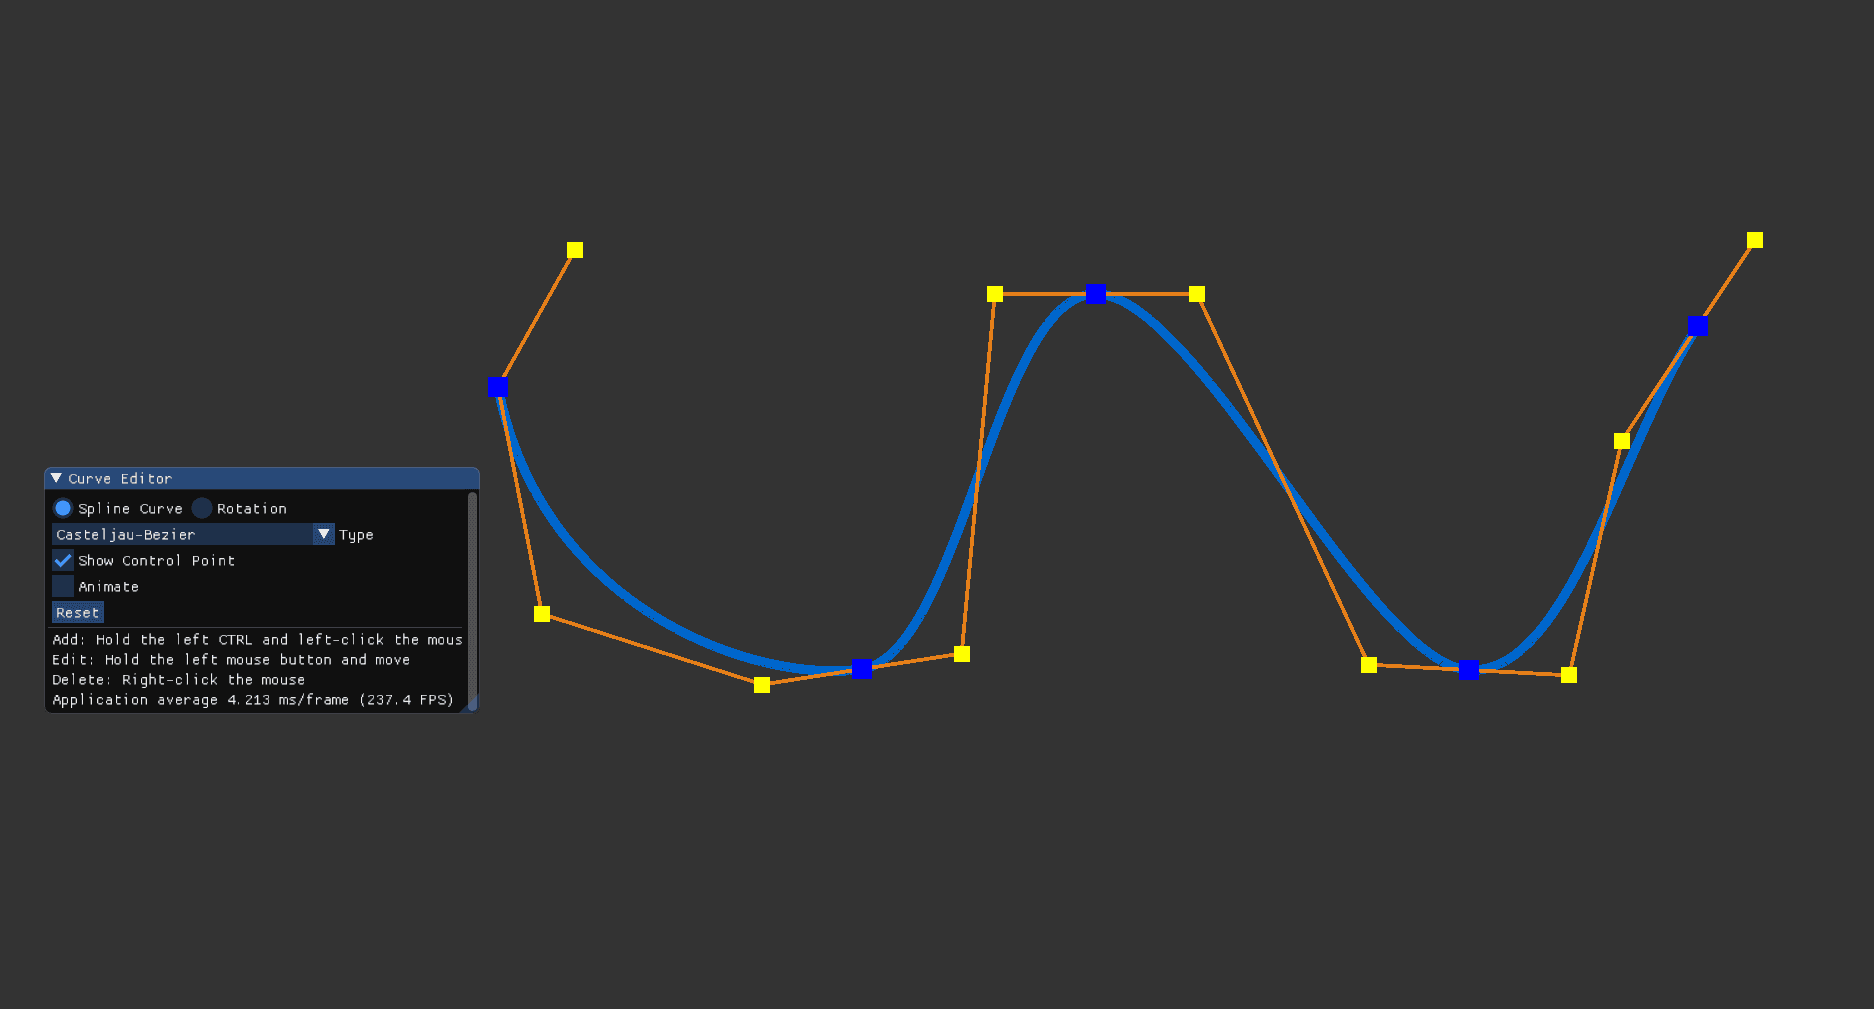
In this project, I implemented some basic functions with Forward Kinematics & Inverse Kinematics.
Foward Kinematics
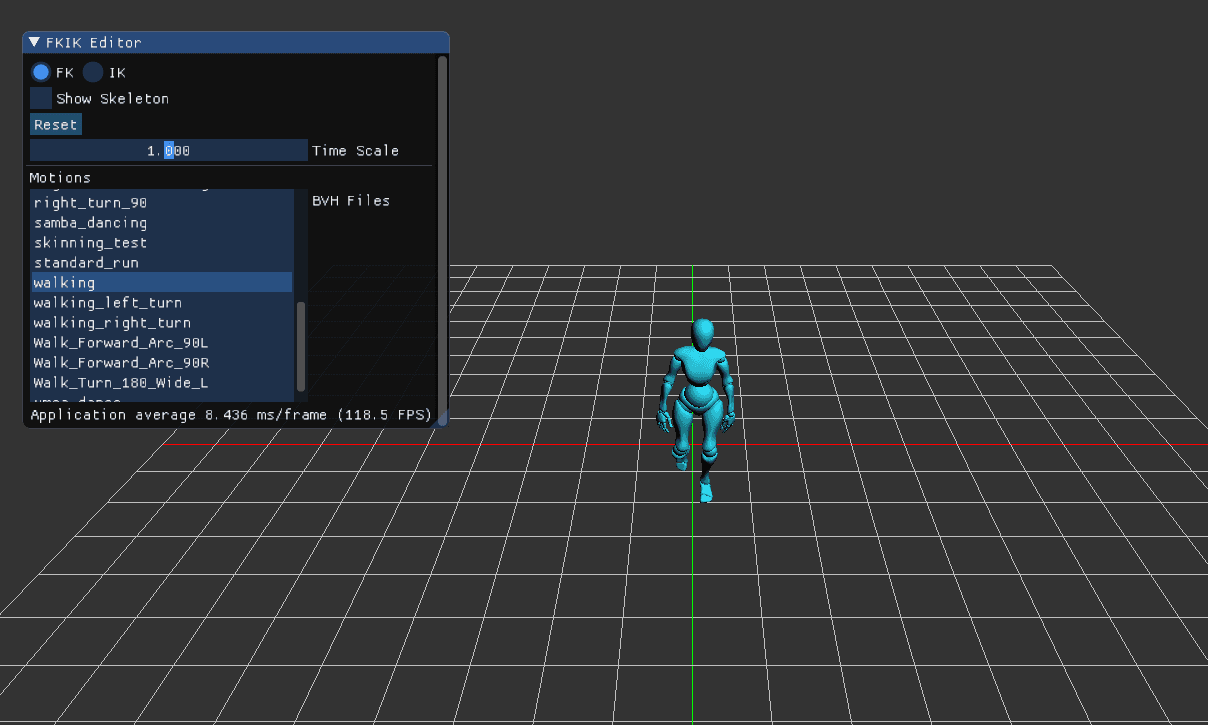
Implemented basic FK logic:
Inverse Kinematics
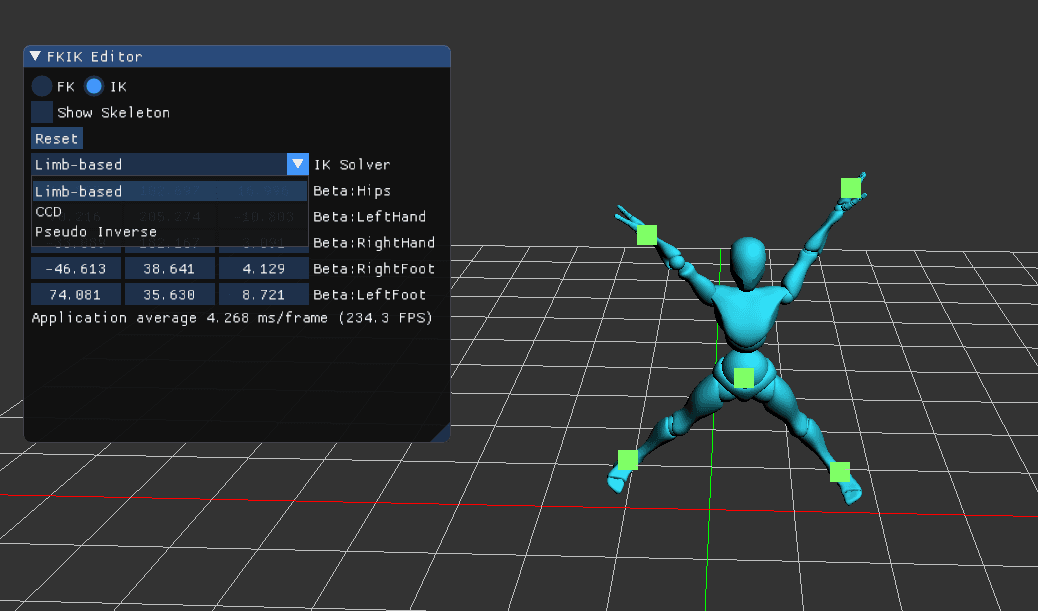
Implemented Inverse Kinematics with serveral methods:
- Limb-based
- CCD (Cyclic Coordinate Descent)
- Pseudo-Inverse
Foot IK
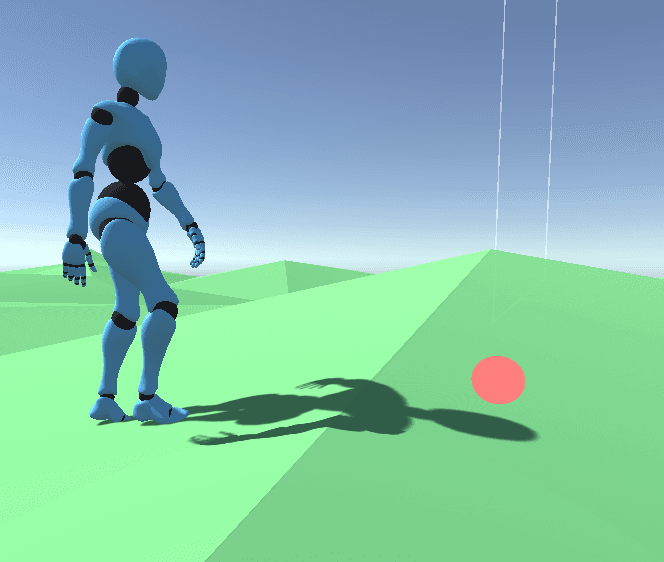
Implemented the guide point logic in Unity with Foot IK to make character keep walking smoothly to the target point with foot standing on ground correctly.